Jason Ma
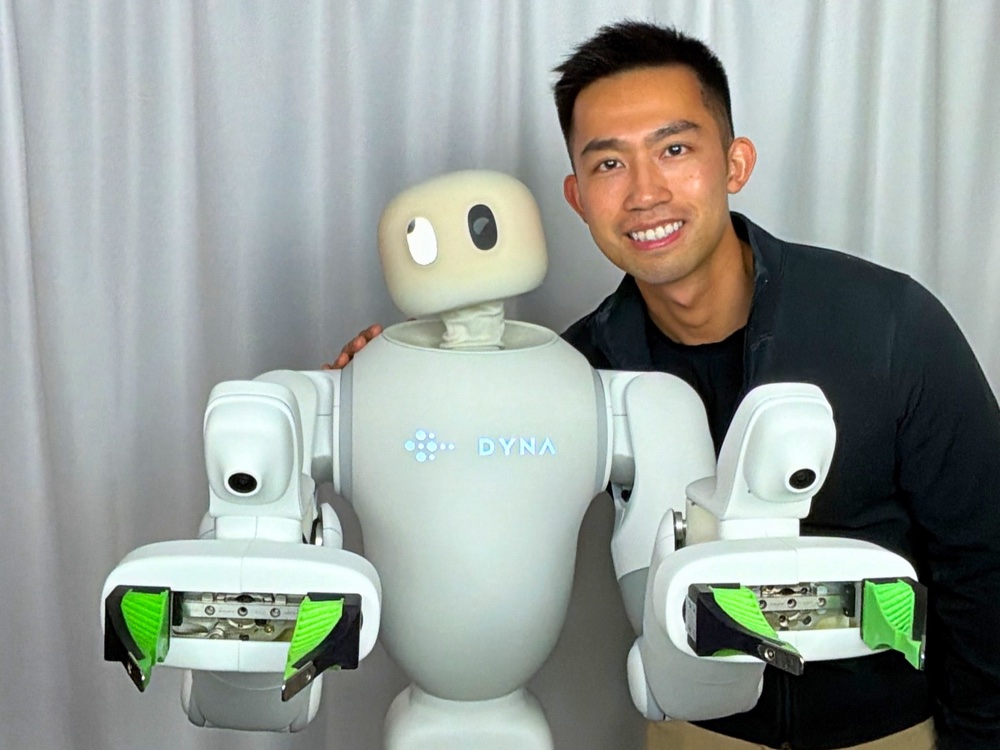
Hi there! I am co-founder and lead research at Dyna, where we are building full-stack, general AI robots.
We are pushing towards a world of physical abundance by combining frontier robotics research, hardware, and deployments into a single product that can be used by millions.
If you are interested in our work and mission, please reach out!
Recent highlights from our team:
Dyna-2.1: A Physical Agent for End-to-End Workflows
Introducing Taku, our semi-humanoid robot, and a learning system that leverages human experience to take over entire workflows without frequent human intervention.
Dyna-2: A 1-Million-Hour Scaling Law for WAMs
A world-action model pre-trained on over one million hours of egocentric human video, exhibiting the first human-to-robot transfer scaling law.
Not Just a Model, But a Product
Dyna has scaled deployments across multiple tasks and customers, from restaurants and hotels to logistics and data centers. Din Tai Fung is now expanding Dyna's robots to all of its locations and commissaries.
Selected recent talks on our research and deployment progress:
Building Embodied AGI Through High-Performance Robots That Scale (Fellows Forum, Sep 2026)
Dyna-2: A One Million Hour Scaling Law for World-Action Models (Actuate, Aug 2026)
Google Scholar
Github
LinkedIn
Twitter
yechengma at gmail dot com
The rest of this page is no longer maintained as of 2026.
Prior to Dyna, I was a researcher at Google DeepMind, NVIDIA AI, and Meta AI.
I completed my PhD at Penn, focusing on large-scale reinforcement learning methods for robot learning.
Even earlier, I studied CS and math at Harvard.
Selected honors:
- • RSS Pioneers, 2025
- • Apple Scholars in AI/ML PhD Fellowship, 2024
- • OpenAI Superalignment PhD Felowship, 2024
- • ICRA Best Paper Finalist in Robot Vision, 2024
- • NVIDIA Top 10 Research Project of Year, 2023
My research has pioneered new algorithms for training and leveraging foundation models from internet data to teach robots new tasks. Specifically, my research has
- • introduced a new paradigm of scaling large language models (LLMs) test-time compute to automate sim-to-real robot learning (ICLR 2024; NVIDIA Top 10 Research Project of Year 2023, RSS 2024, CORL 2024 Oral)
- • developed scalable and principled reinforcement learning algorithms that leverage human videos to learn visual rewards for self-improving robotic manipulation (ICLR 2023 Spotlight, ICRA 2024 Best Paper Finalist in Robot Vision; CORL 2023 LEAP Workshop Best Paper, ICRA 2025)
- • demonstrated how to best combine multi-modal learning and RL to train and utilize vision-language models (VLMs) for universal value functions (ICML 2023, ICLR 2025 Spotlight)
(* indicates equal contribution, † indicates equal advising)
Vision-Language Models are In-Context Value Learners
Jason Ma*, Joey Hejna, Ayzaan Wahid, Chuyuan Fu, Dhruv Shah, Jacky Liang, Zhuo Xu, Sean Kirmani, Peng Xu, Danny Driess, Ted Xiao, Jonathan Tompson, Osbert Bastani, Dinesh Jayaraman, Wenhao Yu, Tingnan Zhang, Dorsa Sadigh, Fei Xia
International Conference on Learning Representations (ICLR), 2025 (Spotlight)
Webpage •
Arxiv •
Articulate-Anything: Automatic Modeling of Articulated Objects via Vision-Language Models
Long Le, Jason Xie, William Liang, Hung-Ju Wang, Yue Yang, Jason Ma, Kyle Vedder, Arjun Krishna, Dinesh Jayaraman, Eric Eaton
International Conference on Learning Representations (ICLR), 2025
Webpage •
Arxiv •
Code
Eurekaverse: Environment Curriculum Generation via Large Language Models
William Liang, Sam Wang, Hungju Wang, Osbert Bastani, Dinesh Jayaraman†, Jason Ma†
Conference on Robot Learning (CoRL) (Oral) , 2024
Webpage •
Arxiv •
Code
On-Robot Reinforcement Learning with Goal-Contrastive Rewards
Ondrej Biza, Thomas Weng, Lingfeng Sun, Karl Schmeckpeper, Tarik Kelestemur, Jason Ma†, Robert Platt†, Jan-Willem van de Meent†, Lawson L. S. Wong†
International Conference on Robotics and Automation (ICRA), 2025
Arxiv •
DrEureka: Language Model Guided Sim-To-Real Transfer
Jason Ma*, William Liang*, Hungju Wang, Sam Wang, Yuke Zhu, Linxi "Jim" Fan, Osbert Bastani, Dinesh Jayaraman
Robotics: Science and Systems (RSS), 2024
Webpage •
Arxiv •
Code
Eureka: Human-Level Reward Design via Coding Large Language Models
Jason Ma, William Liang, Guanzhi Wang, De-An Huang, Osbert Bastani, Dinesh Jayaraman, Yuke Zhu, Linxi "Jim" Fan†, Anima Anandkumar†
International Conference on Learning Representations (ICLR), 2024
NVIDIA Top 10 Research Projects of 2023
Webpage •
Arxiv •
Code
Universal Visual Decomposer: Long-Horizon Manipulation Made Easy
Charles Zhang*, Yunshuang Li*, Osbert Bastani, Abhishek Gupta, Dinesh Jayaraman, Jason Ma†, Lucas Weihs†
International Conference on Robotics and Automation (ICRA) (Best Paper Finalist) , 2024
Best Paper Award, CORL 2023 LEAP Workshop
Webpage •
Arxiv •
Code
LIV: Language-Image Representations and Rewards for Robotic Control
Jason Ma, Vikash Kumar, Amy Zhang, Osbert Bastani, Dinesh Jayaraman
International Conference on Machine Learning (ICML), 2023
Webpage •
Arxiv •
Code
VIP: Towards Universal Visual Reward and Representation via Value-Implicit Pre-Training
Jason Ma, Shagun Sodhani, Dinesh Jayaraman, Osbert Bastani, Vikash Kumar†, Amy Zhang†
International Conference on Learning Representations (ICLR) (Spotlight) , 2023
Best Paper Finalist, NeurIPS 2022 Deep RL Workshop
Webpage •
Arxiv •
Code
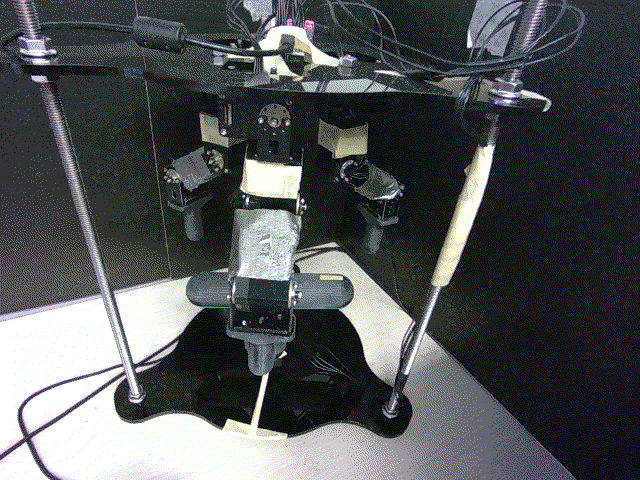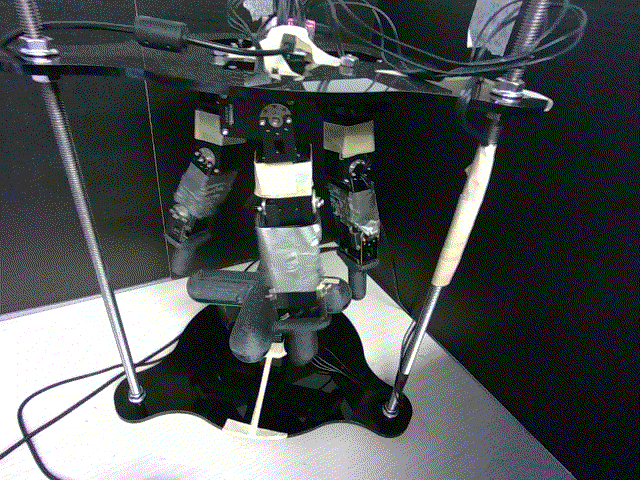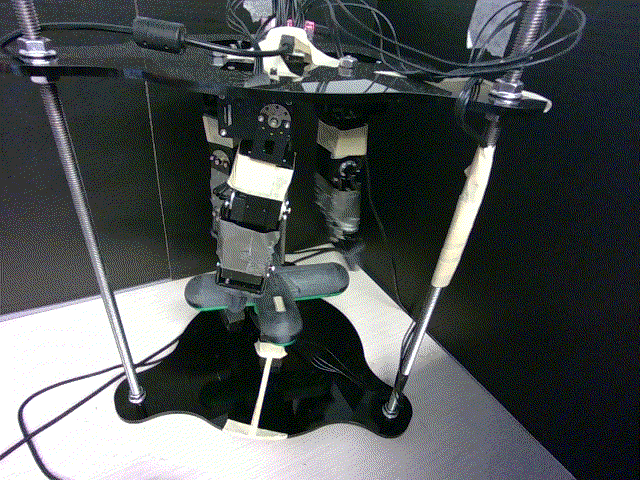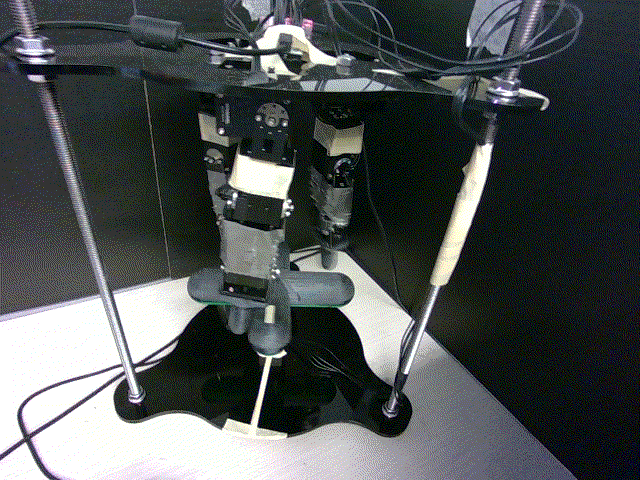
How Far I'll Go: Offline Goal-Conditioned RL via F-Advantage Regression
Jason Ma, Jason Yan, Dinesh Jayaraman, Osbert Bastani
Neural Information Processing Systems (NeurIPS) (Nominated for Outstanding Paper) , 2022
Webpage •
Arxiv •
Code
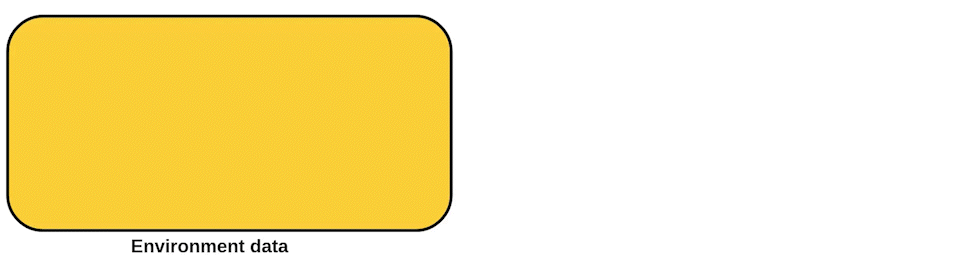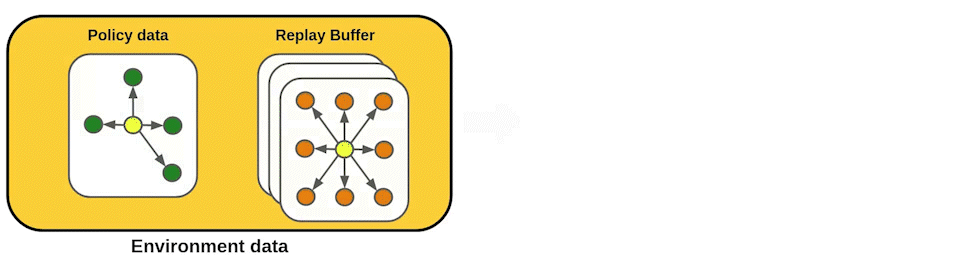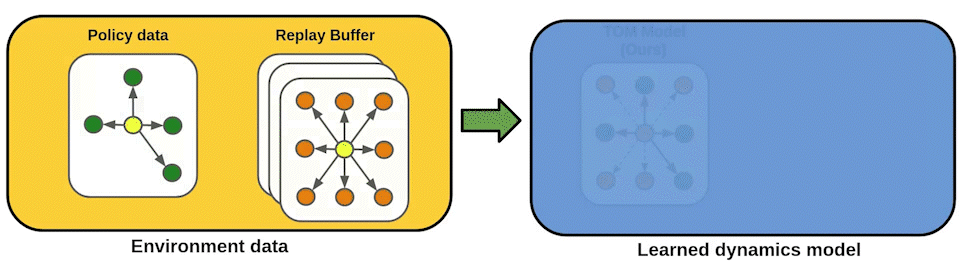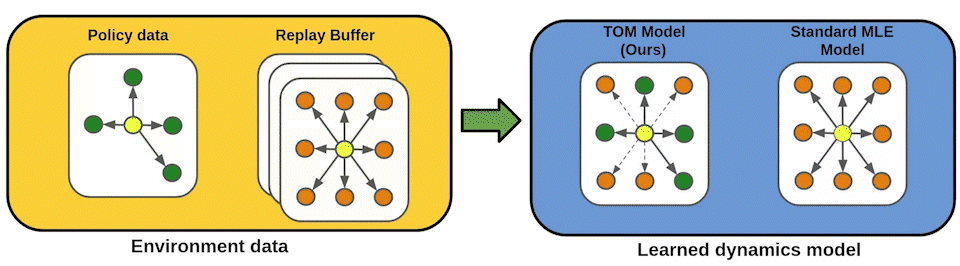
TOM: Learning Policy-Aware Models for MBRL via Transition Occupancy Matching
Jason Ma*, Kausik Sivakumar*, Jason Yan, Osbert Bastani, Dinesh Jayaraman
Learning for Decision and Control (L4DC), 2023
Webpage •
Arxiv •
Code
SMODICE: Versatile Offline Imitation from Observations and Examples
Jason Ma, Andrew Shen, Dinesh Jayaraman, Osbert Bastani
International Conference on Machine Learning (ICML), 2022
Webpage •
Arxiv •
Code
CAP: Conservative and Adaptive Penalty for Model-Based Safe Reinforcement Learning
Jason Ma*, Andrew Shen*, Osbert Bastani, Dinesh Jayaraman
Association for the Advancement of Artificial Intelligence (AAAI), 2022
Arxiv •
Code
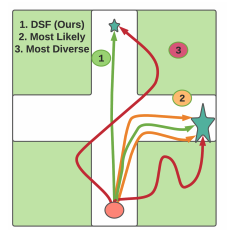
Likelihood-Based Diverse Sampling for Trajectory Forecasting
Jason Ma, Jeevana Priya Inala, Dinesh Jayaraman, Osbert Bastani
International Conference on Computer Vision (ICCV), 2021
Arxiv •
Code
Conservative Offline Distributional Reinforcement Learning
Jason Ma, Dinesh Jayaraman, Osbert Bastani
Neural Information Processing Systems (NeurIPS), 2021
Arxiv •
Code
2025
UC Berkeley, December 20252024
MIT Embodied Intelligence Seminar2023
MIT IAI Lab2022
University of Edinburgh RL Seminar2024
Co-Organizer, RSS Workshop on Task Specification for General-Purpose Intelligent Robots2023
Co-Organizer, NeurIPS Workshop on Goal-Conditioned Reinforcement Learning2023
Co-Organizer, GRASP Student, Faculty, and Industry (SFI) Seminar2021+
Reviewer, NeurIPS, ICML, ICLR, AAAI, ICRA, IROS, RA-L, CORLPast
William Liang (now PhD at UC Berkeley)